RoboMME#
← Tutorial Library · Simulation and Benchmarks
This section introduces the general functions of LeRobot. Please configure the example according to the target robot, data set and operating environment; before using it with AlohaMini 2 / 2 Pro, you need to confirm the hardware and interface compatibility.
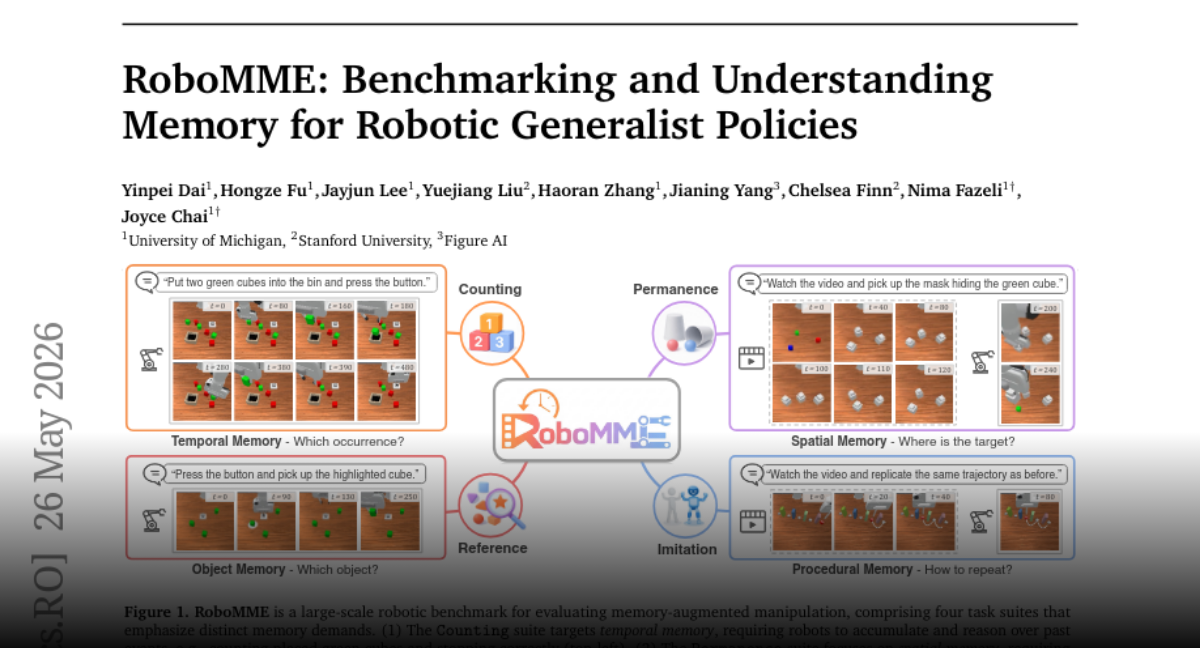
RoboMME is a memory-augmented manipulation benchmark built on ManiSkill (SAPIEN). It evaluates a robot’s ability to retain and use information across an episode — counting, object permanence, reference, and imitation.
16 tasks across 4 memory-skill suites
1,600 training demos (100 per task, 50 val, 50 test)
Dataset:
lerobot/robomme— LeRobot v3.0, 768K frames at 10 fpsSimulator: ManiSkill / SAPIEN, Panda arm, Linux only
Tasks#
Suite |
Tasks |
|---|---|
Counting (temporal memory) |
BinFill, PickXtimes, SwingXtimes, StopCube |
Permanence (spatial memory) |
VideoUnmask, VideoUnmaskSwap, ButtonUnmask, ButtonUnmaskSwap |
Reference (object memory) |
PickHighlight, VideoRepick, VideoPlaceButton, VideoPlaceOrder |
Imitation (procedural memory) |
MoveCube, InsertPeg, PatternLock, RouteStick |
Installation#
RoboMME requires Linux (ManiSkill/SAPIEN uses Vulkan rendering). Docker is recommended to isolate dependency conflicts.
Native (Linux)#
pip install --override <(printf 'gymnasium==0.29.1\nnumpy==1.26.4\n') \
  -e '.[smolvla,av-dep]' \
  'robomme @ git+https://github.com/RoboMME/robomme_benchmark.git@main'
Dependency note:
mani-skill(pulled byrobomme) pinsgymnasium==0.29.1andnumpy<2.0.0, which conflict with lerobot’s basenumpy>=2.0.0. That’s whyrobommeis not a pyproject extra — use the override install above, or the Docker approach below to avoid conflicts entirely.
Docker (recommended)#
# Build base image first (from repo root)
docker build -f docker/Dockerfile.eval-base -t lerobot-eval-base .

# Build RoboMME eval image (applies gymnasium + numpy pin overrides)
docker build -f docker/Dockerfile.benchmark.robomme -t lerobot-robomme .
The docker/Dockerfile.benchmark.robomme image overrides gymnasium==0.29.1 and numpy==1.26.4 after lerobot’s install. Both versions are runtime-safe for lerobot’s actual API usage.
Running Evaluation#
Default (single task, single episode)#
lerobot-eval \
    --policy.path=<your_policy_repo> \
    --env.type=robomme \
    --env.task=PickXtimes \
    --env.dataset_split=test \
    --env.task_ids=[0] \
    --eval.batch_size=1 \
    --eval.n_episodes=1
Multi-task evaluation#
Evaluate multiple tasks in one run by comma-separating task names. Use task_ids to control which episodes are evaluated per task. Recommended: 50 episodes per task for the test split.
lerobot-eval \
    --policy.path=<your_policy_repo> \
    --env.type=robomme \
    --env.task=PickXtimes,BinFill,StopCube,MoveCube,InsertPeg \
    --env.dataset_split=test \
    --env.task_ids=[0,1,2,3,4,5,6,7,8,9] \
    --eval.batch_size=1 \
    --eval.n_episodes=50
Key CLI options for env.type=robomme#
Option |
Default |
Description |
|---|---|---|
|
|
Any of the 16 task names above (comma-separated) |
|
|
|
|
|
|
|
|
Max steps per episode |
|
|
List of episode indices to evaluate (null = |
Dataset#
The dataset lerobot/robomme is in LeRobot v3.0 format and can be loaded directly:
from lerobot.datasets.lerobot_dataset import LeRobotDataset

dataset = LeRobotDataset("lerobot/robomme")
Dataset features#
Feature |
Shape |
Description |
|---|---|---|
|
(256, 256, 3) |
Front camera RGB |
|
(256, 256, 3) |
Wrist camera RGB |
|
(8,) |
Joint angles + gripper |
|
(8,) |
Joint positions + gripper state |
|
str |
High-level language annotation |
|
str |
Grounded language annotation |
|
int |
Episode ID |
|
int |
Frame within episode |
Feature key alignment (training)#
The env wrapper exposes pixels/image and pixels/wrist_image as observation keys. The features_map in RoboMMEEnv maps these to observation.images.image and observation.images.wrist_image for the policy. State is exposed as agent_pos and maps to observation.state.
The dataset’s image and wrist_image columns already align with the policy input keys, so no renaming is needed when fine-tuning.
Action Spaces#
Type |
Dim |
Description |
|---|---|---|
|
8 |
7 joint angles + 1 gripper (−1 closed, +1 open, absolute) |
|
7 |
xyz + roll/pitch/yaw + gripper |
Set via --env.action_space=joint_angle (default) or --env.action_space=ee_pose.
Platform Notes#
Linux only: ManiSkill requires SAPIEN/Vulkan. macOS and Windows are not supported.
GPU recommended: Rendering is CPU-capable but slow; CUDA + Vulkan gives full speed.
gymnasium / numpy conflict: See installation note above. Docker image handles this automatically.
ManiSkill fork:
robommedepends on a specific ManiSkill fork (YinpeiDai/ManiSkill), pulled in automatically via therobommepackage.