AlohaMini#
← Tutorial Library · AlohaMini Hardware and Operation
Please confirm the applicable models based on the hardware configuration on this page.
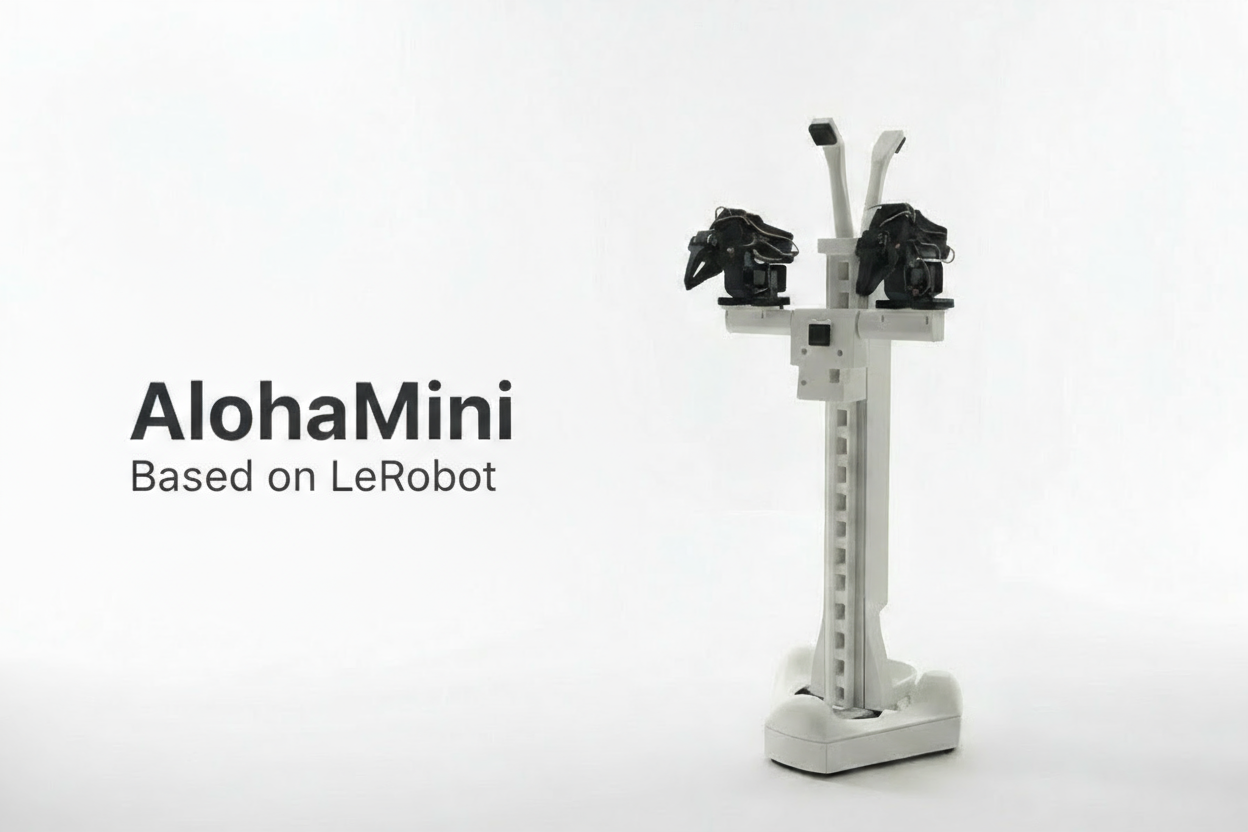
AlohaMini is a dual-arm mobile robot with a motorized vertical lift — beautifully designed, fully 3D-printable, and affordable.
Built for embodied AI research and real-world manipulation. Assemble at home in ~60 minutes, customize every part, and train or deploy with LeRobot.
Note: Use ROS only if you need URDF visualization, RViz inspection, or Gazebo simulation.
Updates#
[2026-02-26] Update the fine-tuning and deployment guide for Pi 0.5 on Alohamini (‘examples/pi0.5_openpi’)
[2025-12-18] URDF and simulation assets are now available for visualization and simulation (
simulation/src/Aloha/)[2025-11-27] STEP (CAD) files are now available (
/hardware/mobile_base/step/)
What Makes It Different#
Motorized vertical lift — 0–60 cm travel (floor-to-table reach)
5-camera perception system — top, front, back, and dual arm cameras engineered for embodied-AI reproducibility
Completely open-source — hardware and software freely available
LeRobot-compatible — works out of the box
Clean, modern design — built for both function and aesthetics
Low-cost & accessible — engineered so anyone can build a capable robot at home
📸 Gallery#
⚙️ Bill of Materials (BOM)#
Main Components#
Component |
Model / Notes |
Qty |
Unit Price (USD) |
|---|---|---|---|
Servo motors |
Feetech STS3215 (12V bus) |
16 |
$13.89 |
Motor control boards |
Waveshare Bus Servo Adapter (A) |
2 |
$10.55 |
Compute platform |
Raspberry Pi 5 (4/8GB) |
1 |
$80 |
Cameras |
720p USB cameras (2 for arms, 3 for mobile base) |
5 |
$20 |
Mobility system |
Omni wheels |
3 |
$36.00 |
Battery |
12V Li-ion pack |
2 |
$32.99 |
Frame |
3D-printed body (ABS / PETG / PLA) |
— |
~4kg filament (self-print) |
Total |
— |
— |
~$600 (self-print) |
Note:
Printable STL files under
/hardware/Compute platform can be replaced with Jetson Nano or similar SBCs if desired.
URDF files will be released soon
Quick Start#
Start building and running AlohaMini:
Hardware acquisition — Purchase components and 3D print parts
See BOM & 3D-PrintAssembly — build the robot in ~60 minutes (SO-ARM pre-assembled)
See assembly guideSoftware setup & teleoperation — install, connect, and control the robot
See software guide
Product Line#
Model |
Build |
Rigidity |
Target Users |
Official Store (US) |
Official Store (CN) |
|---|---|---|---|---|---|
AlohaMini |
Fully 3D-printed |
Standard |
Education, makers, research labs, home builds |
- |
|
AlohaMini Pro |
Hybrid 3D-print + metal |
~3×–5× stiffer |
Researchers needing plug-and-play, stable hardware |
- |
Same URDF & control stack across both versions — only structural materials differ.
Official store links are optional purchase channels for complete robots / kits.
AlohaMini remains open-source and can be self-built from the BOM, 3D-print files, and assembly docs.
Contact#
Email: liyiteng+github@gmail.com
WeChat: liyiteng
Videos & tutorials soon on: Bilibili / YouTube / TikTok
Team#
AlohaMini is created by:
Li Yiteng / Wu Zhiyong
Acknowledgements#
Thanks to the open robotics community:
ALOHA · LeKiwi · SO-ARM100 · SO-ARM100-Track-Axis · Pi-0.5 · LeRobot · Hugging Face
⭐ Support AlohaMini#
If you like this project:
⭐ Star the repo
🔔 Follow updates
💬 Join the community